

UnderAutomation.ABB is a fully managed .NET SDK that talks to ABB industrial robot controllers over Robot Web Services (RWS). It works the same way on IRC5 (RobotWare 6) and on OmniCore (RobotWare 7). Nothing is installed on the controller. No RobotStudio, no PC SDK, no ABB runtime.
Use it to read and write RAPID variables, control I/O, read positions, jog the robot, manage programs, files and backups, and follow the state of the controller, from a normal .NET application.
- Product page: underautomation.com/abb
- Documentation: underautomation.com/abb/documentation
- Also available for Python: ABB.py
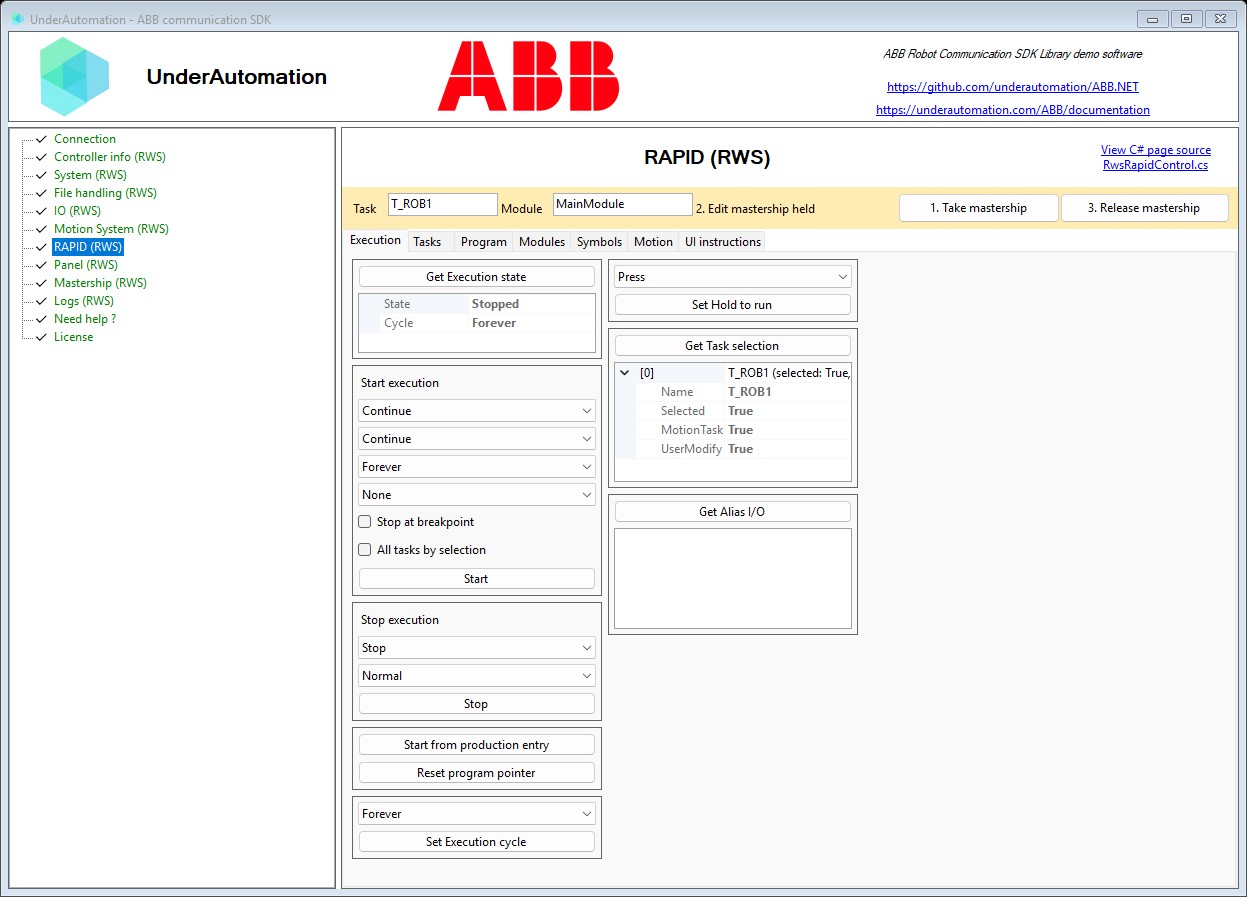
- RAPID variables and programs: read and write variables, persistents and constants, including
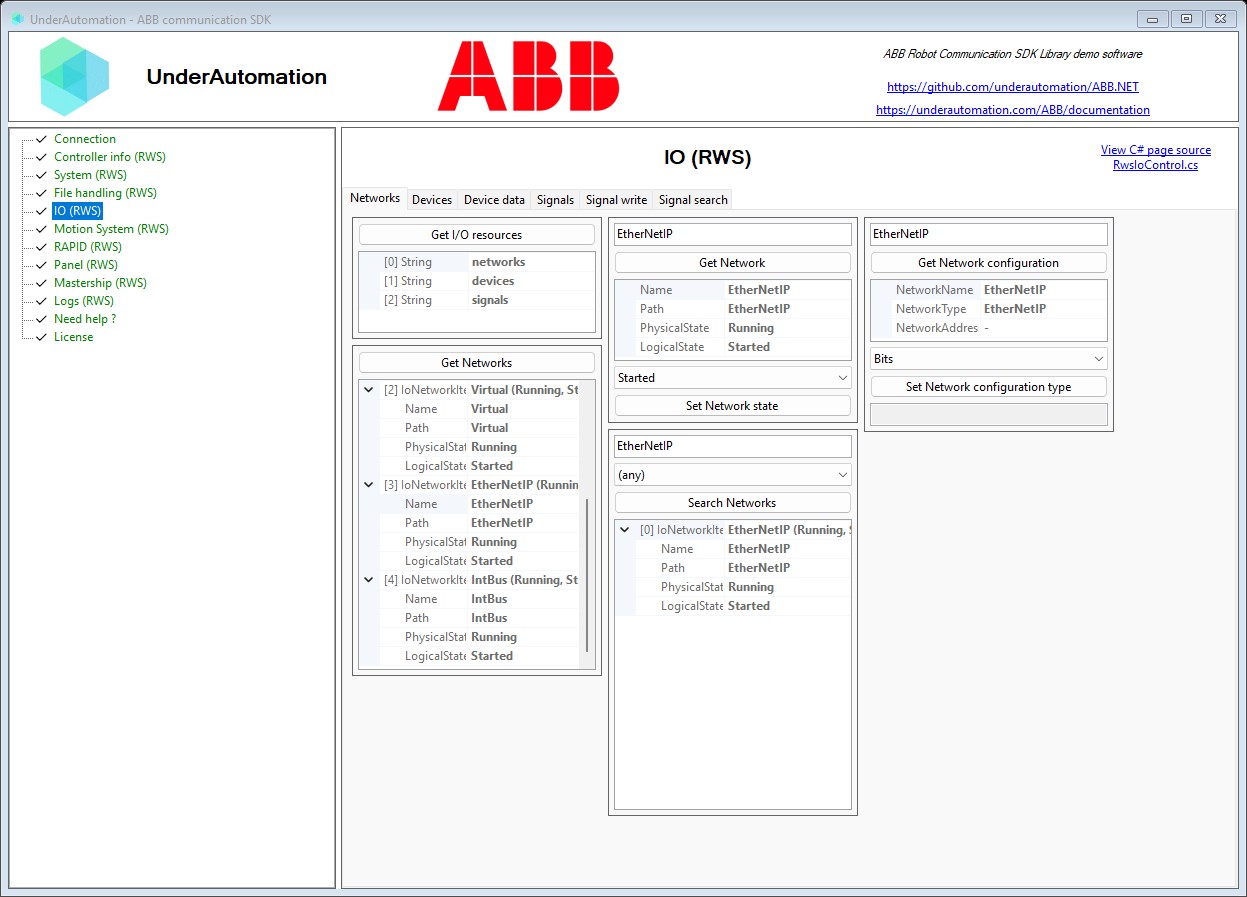
robtargetand record types. Start and stop tasks, move the program pointer, load and save modules, search the symbols of the loaded program. - Inputs / Outputs: list, read and write digital, analog and group signals. Pulse, invert or simulate a signal. Browse and configure I/O devices and networks.
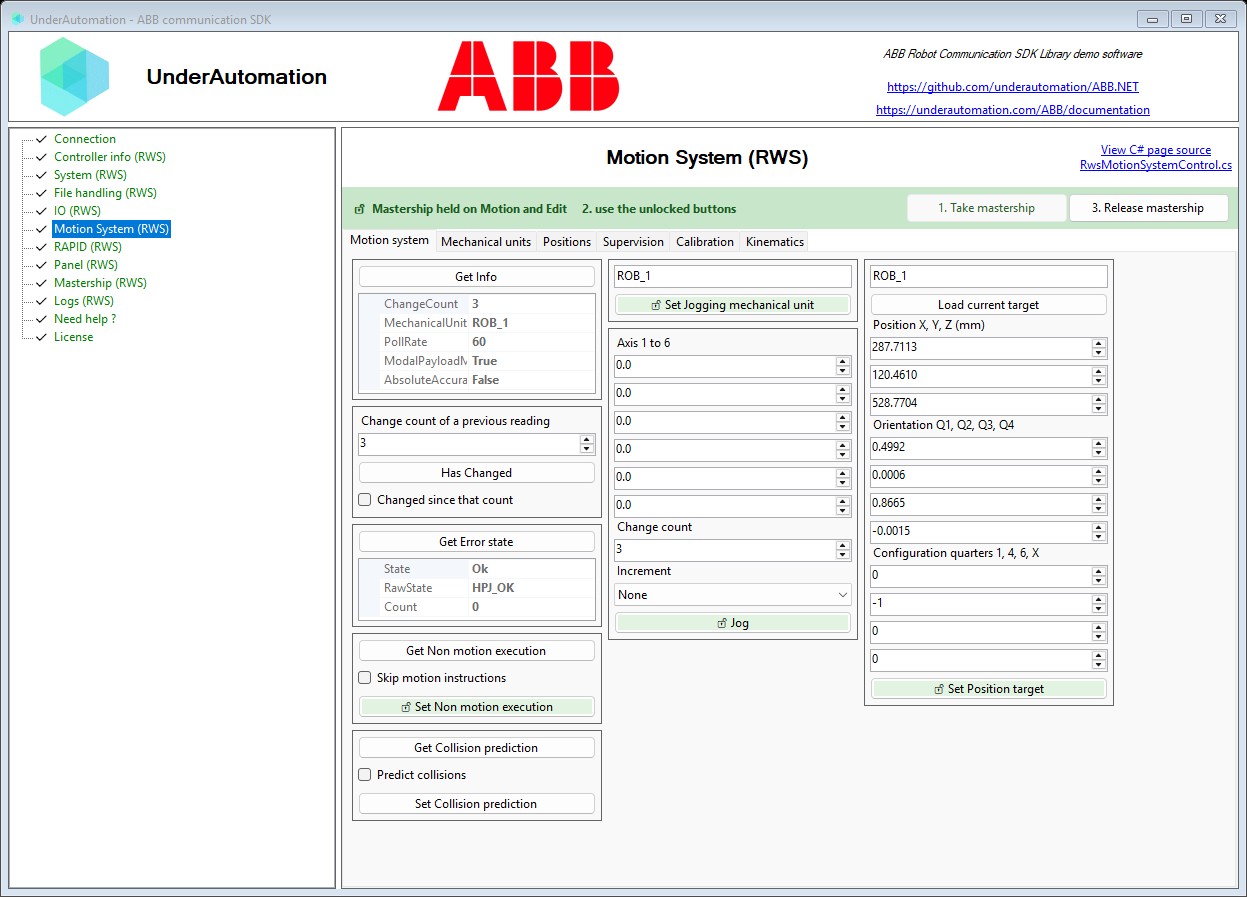
- Position and kinematics: read the current
robtargetandjointtarget, convert between Cartesian pose and joint values, jog the robot, set a position target. - Controller and state: read the identity and the options, follow the operation mode, the controller state and the speed ratio, set the clock, the language and the network.
- Backup and restore: create a full backup, check it, and restore it.
- File system: browse the controller file system, download and upload files, create, copy, rename and delete files and directories.
- Event log: read the event log by domain, in the language you ask, and clear it.
- System and energy: read the system product list, the options and the energy counters.
- Mastership: request and release the edit and motion mastership, explicitly or implicitly.
- Discovery: find the ABB controllers of the local network, and the virtual controllers running on this machine, without a license and without a known address.
- One API for both controller generations: the same code runs on IRC5 (RWS 1.0) and on OmniCore (RWS 2.0). Only one connection parameter changes.
- Sync and async: every service method has a synchronous version and, from .NET Framework 4.5 on,
an
...Asyncversion that takes aCancellationToken.
No ABB option is required on the controller. Robot Web Services is part of a standard system.
A Windows Forms application shows every feature of the SDK. Its source code is in this repository, in
UnderAutomation.ABB.Showcase.Forms.
Download: UnderAutomation.ABB.Showcase.Forms.exe (all releases)
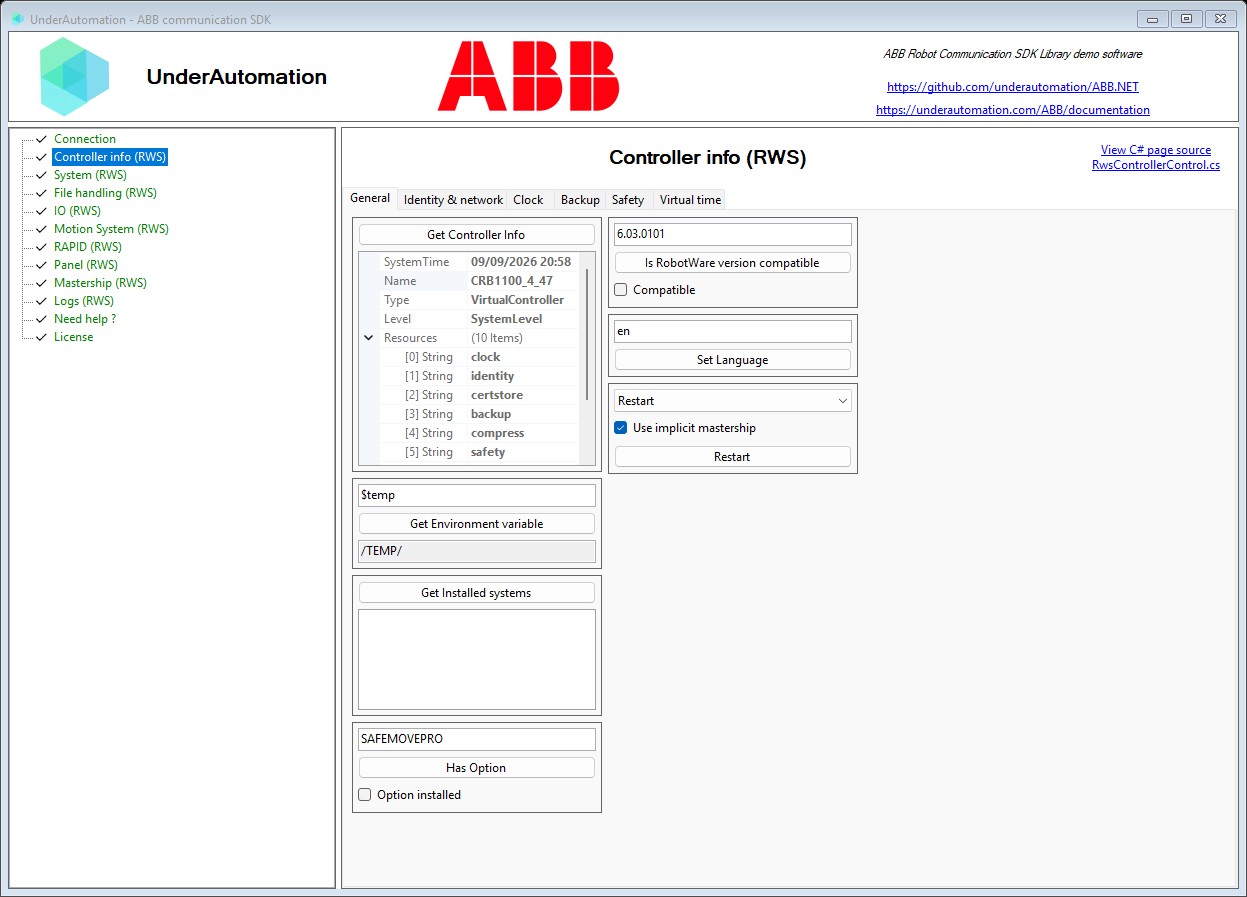
Controller, backup and state
RAPID variables and programs
Inputs / Outputs
Position and kinematics
dotnet add package UnderAutomation.ABBOr with the NuGet Package Manager console:
Install-Package UnderAutomation.ABB
You can also download UnderAutomation.ABB.zip from the releases page.
It contains one folder per target framework. On Windows, unblock the zip file before you extract it
(right-click, "Properties", "Unblock"), then reference the DLL of your framework.
using UnderAutomation.ABB;

// The SDK runs in trial mode for 30 days. Register your key to remove the trial limit.
AbbController.RegisterLicense("Your Company", "your-license-key");

var robot = new AbbController();
robot.Connect("192.168.125.1");

var identity = robot.Rws.Controller.GetIdentity();
Console.WriteLine(identity.Name);

robot.Disconnect();The default is OmniCore (RWS 2.0). For an IRC5 controller, set the version to RwsVersion.Irc5_V1_0.
The rest of your code does not change.
var parameters = new ConnectionParameters("192.168.125.1");
parameters.Rws.Username = "Default User";
parameters.Rws.Password = "robotics";
parameters.Rws.UseHttps = true;                     // OmniCore is reached over HTTPS
parameters.Rws.Version  = RwsVersion.OmniCore_V2_0; // or RwsVersion.Irc5_V1_0 for IRC5

var robot = new AbbController();
robot.Connect(parameters);Everything is reached through robot.Rws, grouped by service:
Controller, Io, Rapid, MotionSystem, Panel, System, File, Elog, Mastership.
// Read a RAPID symbol, the value comes back the way RAPID writes it
var reg1 = robot.Rws.Rapid.GetSymbolValue("RAPID/T_ROB1/user/reg1");
Console.WriteLine(reg1.Value);

// Write a symbol (needs the edit mastership in automatic mode)
robot.Rws.Mastership.Request(MastershipDomain.Edit);
robot.Rws.Rapid.SetSymbolValue("RAPID/T_ROB1/user/reg1", "42");
robot.Rws.Mastership.Release();

// Start and stop the program
robot.Rws.Rapid.Start();
robot.Rws.Rapid.Stop();

// Load a module, list tasks, follow the execution state
robot.Rws.Rapid.LoadModule("T_ROB1", "HOME:/mymodule.mod", replace: true);
var tasks = robot.Rws.Rapid.GetTasks();
var state = robot.Rws.Rapid.GetExecutionState();// List every signal
IoSignalItem[] signals = robot.Rws.Io.GetSignals();
// Read one signal
IoSignalItem di1 = robot.Rws.Io.GetSignal("EtherNetIP", "d652", "DI_01");
Console.WriteLine(di1.LogicalValue);
// Write, pulse or invert an output
robot.Rws.Io.SetSignalValue("EtherNetIP", "d652", "DO_01", 1);
robot.Rws.Io.PulseSignal("EtherNetIP", "d652", "DO_01", 1, pulses: 3);
robot.Rws.Io.InvertSignal("EtherNetIP", "d652", "DO_01", 1);
// Simulate a signal so a value can be forced without hardware
robot.Rws.Io.SetSignalState("EtherNetIP", "d652", "DI_01", simulated: true);// Current Cartesian and joint position of a mechanical unit
RobTarget robTarget = robot.Rws.MotionSystem.GetRobTarget("ROB_1");
JointTarget jointTarget = robot.Rws.MotionSystem.GetJointTarget("ROB_1");
Console.WriteLine($"X={robTarget.X} Y={robTarget.Y} Z={robTarget.Z}");
Console.WriteLine($"J1={jointTarget.RobotAxes.Axis1} J2={jointTarget.RobotAxes.Axis2}");
// Convert a Cartesian pose to joint values
JointTarget joints = robot.Rws.MotionSystem.GetJointsFromCartesian("ROB_1", pose, externalAxes);
// Jog the robot
robot.Rws.MotionSystem.SetJoggingMechanicalUnit("ROB_1");
robot.Rws.MotionSystem.Jog(new RobotJoints { Axis1 = 5 }, changeCount: 0);// Finds the controllers of the local network and the virtual controllers of this machine.
// No connection is opened and no license is needed.
DiscoveredController[] found = AbbController.Discover();
foreach (var controller in found)
Console.WriteLine($"{controller.SystemName} at {controller.Address}:{controller.Port}");
// ToConnectionParameters carries the address, the port, the scheme and the RWS version found
var robot = new AbbController();
robot.Connect(found[0].ToConnectionParameters());ControllerIdentity id = robot.Rws.Controller.GetIdentity();
ControllerInfo info = robot.Rws.Controller.GetInfo();
OperationMode mode = robot.Rws.Panel.GetOperationMode();
ControllerState state = robot.Rws.Panel.GetControllerState();
int speedRatio = robot.Rws.Panel.GetSpeedRatio();
robot.Rws.Panel.SetSpeedRatio(50);
robot.Rws.Controller.SetClock(DateTime.Now);
bool hasOption = robot.Rws.Controller.HasOption("RobotWare-OS");robot.Rws.Controller.CreateBackup("HOME:/backups/2026-01-15");
CheckRestoreResult check = robot.Rws.Controller.CheckRestore("HOME:/backups/2026-01-15");
if (check.IsAccepted)
robot.Rws.Controller.RestoreBackup("HOME:/backups/2026-01-15");DirectoryListing listing = robot.Rws.File.ListDirectory("HOME:/");
foreach (var dir in listing.Directories)
Console.WriteLine(dir.Name);
foreach (var file in listing.Files)
Console.WriteLine($"{file.Name} ({file.Size} bytes)");
robot.Rws.File.UploadFileFromPath("HOME:/mymodule.mod", @"C:\rapid\mymodule.mod");
robot.Rws.File.GetFileToDestination("HOME:/mymodule.mod", @"C:\backup\mymodule.mod");
string text = robot.Rws.File.GetFileAsText("HOME:/mymodule.mod");
robot.Rws.File.DeleteFile("HOME:/old.mod");ElogMessage[] messages = robot.Rws.Elog.GetMessages(domain: 0, language: "en");
foreach (var m in messages)
Console.WriteLine($"{m.Timestamp} {m.Title}");
robot.Rws.Elog.ClearAllMessages();Every method has an async version on .NET Framework 4.5 and later.
var identity = await robot.Rws.Controller.GetIdentityAsync(cancellationToken);
await robot.Rws.Io.SetSignalValueAsync("EtherNetIP", "d652", "DO_01", 1, cancellationToken);ABB robots expose Robot Web Services in two versions. This SDK covers both. The same code runs on an IRC5 and on an OmniCore. Only the connection parameters change.
| Controller | RobotWare | Robot Web Services | RwsVersion value |
|---|---|---|---|
| IRC5 | RobotWare 6 and earlier | RWS 1.0 | RwsVersion.Irc5_V1_0 |
| OmniCore | RobotWare 7 and later | RWS 2.0 | RwsVersion.OmniCore_V2_0 |
HTTP or HTTPS is a separate setting (UseHttps), independent of the controller generation.
The folder UnderAutomation.Abb.ObfuscatedSources contains
every public type and member of the SDK, with its XML documentation. The bodies of the methods are
replaced by "Source is hidden". Use it to:
- browse the public API and its documentation on GitHub;
- jump to a definition from your code editor;
- see the structure of the code that is delivered with a source license.
The source license gives the complete source code of the library, with the Visual Studio solution. See the license page of the documentation.
| Target framework | Supported | Async methods |
|---|---|---|
| .NET 10.0 / 9.0 / 8.0 / 6.0 / 5.0 | yes | yes |
| .NET Core 3.0 | yes | yes |
| .NET Standard 2.1 / 2.0 | yes | yes |
| .NET Framework 4.5 to 4.8 | yes | yes |
| .NET Framework 3.5 / 4.0 | yes | no (sync only) |
- Operating systems: Windows, Linux, macOS.
- No native dependency, no NuGet dependency.
- Controllers: IRC5, OmniCore, and their virtual controllers in RobotStudio.
This SDK needs a commercial license. A 30-day trial starts at the first use, no key needed.
- License agreement: underautomation.com/abb/eula and License.md
- Trial, license key and source license: underautomation.com/abb/documentation/license
- Prices and quote: underautomation.com/abb
- Documentation: underautomation.com/abb/documentation
- Issues: GitHub Issues
- Contact: underautomation.com/contact