







Architect and robotics researcher. I build the perception, geometry and robot software that lets machines work with material that does not come in standard sizes: fractured stone, salvaged shards, irregular logs, offcuts.
Research Assistant at Alfaisal University, Riyadh (digital fabrication and robotic manipulation) · MRAC, IAAC Barcelona · B.Arch, SPA Vijayawada
Portfolio · ORCID · LinkedIn · Instagram
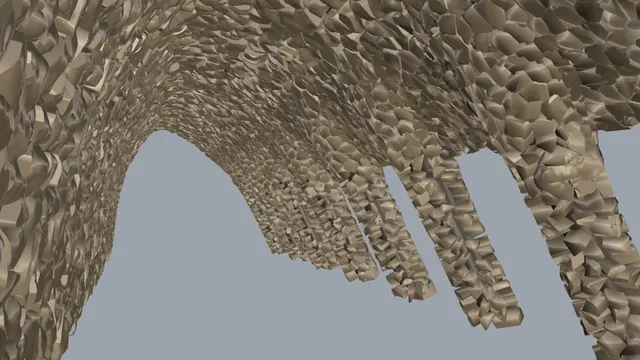
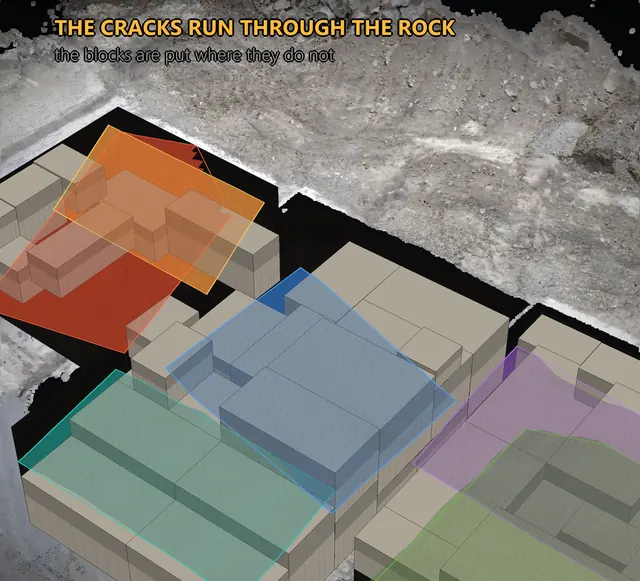
Stone, from quarry to building. I look under the quarry floor with ground-penetrating radar, plan blocks that avoid the cracks, and pack irregular stones into walls, arches and vaults that are checked for stability before anything is cut.
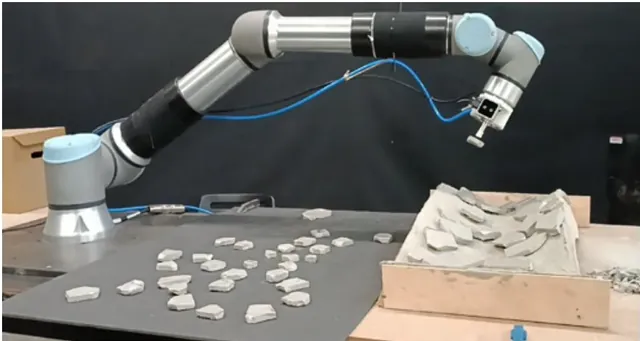
Robotic fabrication with irregular material. Scan-to-fabricate pipelines where a robot sees each piece, plans where it fits and places it: demolition stone, logs, pine offcuts, aluminium sheet.
Sensing and heritage reconstruction. Photogrammetry, monocular depth and registration turned toward temples, stone labyrinths and quarries, released with open code and datasets.
Tools other people can open. A Grasshopper plugin, browser apps for IFC and carving, a robot stack that rebuilds from one Docker image, and agent skills for computational designers.
| Project | What it is | Links |
|---|---|---|
| Frahan StonePack | Rhino 8 / Grasshopper plugin for stone fabrication: 275 components from GPR and scan ingest to block cutting, nesting, masonry, stability checks and IFC / robot export | repo · DOI |
| Kuppam GPR Fracture Study | Radar over three dolerite benches, six fracture surfaces re-tracked (14,315 picks), registered onto photogrammetry, and a straight-cut plan of 42 blocks | live model · repo · dataset |
| Topologic Studio | Browser IFC fire-egress simulation with live re-routing and a Q-learning agent. Original author Wassim Jabi; I extended it | demo · repo |
| UR10e + RG6 stacking | Pick-and-place on ROS 2 Humble + MoveIt 2 in WSL2, sim and real arm, RS-485 gripper bridge, Docker workspace | repo |
| robot_webapp | UR10e controller in the browser: URDF in Three.js, live IK, waypoints, URScript export | repo |
| Digital Pointing Machine | The sculptor's pointing machine rebuilt as an offline web app: exact drill depths from a scan to a stone block | app · repo |
| Temple motif depth | One smartphone photo of a Tamil bas-relief to a watertight STL with Depth Anything 3; 35-panel mesh corpus | repo · corpus |
| Drone photogrammetry of stone labyrinths | Drone video to textured mesh and 3D print, FFmpeg → COLMAP → Open3D in Colab | repo |
| Semi-automatic ICP | Coarse + fine Open3D registration to compare photogrammetry methods | repo |
| stonepacking · aggregation | Small browser experiments in stone packing and rule-based aggregation | stonepacking · aggregation |
| 3DCP research graph | Interactive literature graph and table for 3D concrete printing | open |
The full set, including robotic fabrication studio work from IAAC and IISc, is on the portfolio.
- Alammar, Alymani, Alsofiani, Murugesan, Latif (2026). Towards Climate-Resilient Office Façades: Integrating PCM-Enhanced Glazing with Dynamic External Louvres Under Current and Future Hot–Arid Climates. Sustainability 18(19), 10168. doi:10.3390/su181910168
- Murugesan (2026). A managed, uncertainty-aware pipeline from ground-penetrating radar to dimension-stone block yield in fractured quarries. Research Square preprint, not yet peer reviewed. doi:10.21203/rs.3.rs-10035624/v1
- Murugesan (2026). The Salem Labyrinth: Creating a 3D Model from Drone Footage. Caerdroia 55. PDF
- Murugesan (2025). Two Labyrinths Rediscovered in Salem, India. Caerdroia 54. PDF
- Papandreou, Baseta, Mathe, Blackburn, Murugesan (2022). Programming Twist: Exploring the geometric affordances of aluminum through flexible robotic workflows. eCAADe 2022. doi:10.52842/conf.ecaade.2022.2.399
Datasets and software releases on Zenodo and figshare are listed on the portfolio and ORCID.
- SURE-program_python-intro: summer course scripts, from Python syntax to CAM toolpaths on a simulated robot arm
- Math4Stone: Anki deck of about 1,000 derivation cards for the maths behind scan → CAD → IFC and robotic stone fabrication
- computational-design-skill: agent skills for Grasshopper, Topologic / IFC, fabrication and debugging
- Agent-orchestration: project memory that survives switching between Claude Code, Codex and local models
- Robots: UR10e · KUKA · ABB · ROS 2 · MoveIt 2 · ur_rtde · OnRobot RG6
- Geometry: Rhino 8 · Grasshopper · C# · Python · Three.js · IFC · TopologicPy
- Sensing: GPR · photogrammetry (COLMAP) · Open3D · Depth Anything · OpenCV · RealSense
Interest map from my GitHub stars

Text and images © 2026 Libish Murugesan. Code is under each repository's own license.